LIRRA  1.0.0
Loading...
Searching...
No Matches
rl_stl.envs.skydio_x2.hover.HoverEnvConfig Class Reference
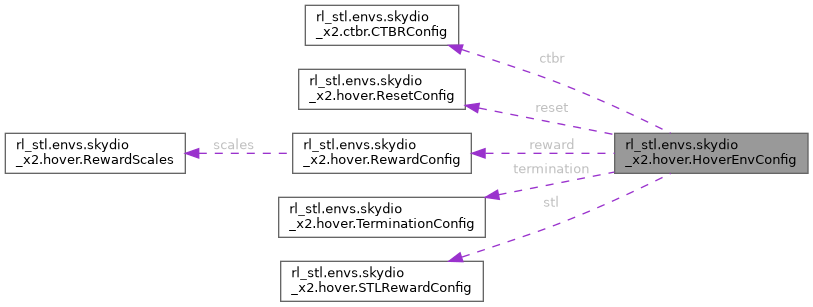
Collaboration diagram for rl_stl.envs.skydio_x2.hover.HoverEnvConfig:

Static Public Attributes

float ctrl_dt = 0.02
 
float sim_dt = 0.01
 
int episode_length = 500
 
str impl = "jax"
 
int naconmax = 0
 
int njmax = 0
 
bool fluid = True
 
bool contacts = False
 
CTBRConfig ctbr = CTBRConfig()
 
tuple target = (0.0, 0.0, 1.5)
 
tuple target_range = (0.0, 0.0, 0.0)
 
ResetConfig reset = ResetConfig()
 
RewardConfig reward = RewardConfig()
 
TerminationConfig termination = TerminationConfig()
 
STLRewardConfig stl = STLRewardConfig()
 

Detailed Description

Single source of truth for the hover env; converted to ``ml_collections`` for Playground.

Member Data Documentation

◆ contacts

bool rl_stl.envs.skydio_x2.hover.HoverEnvConfig.contacts = False
static

◆ ctbr

CTBRConfig rl_stl.envs.skydio_x2.hover.HoverEnvConfig.ctbr = CTBRConfig()
static

◆ ctrl_dt

float rl_stl.envs.skydio_x2.hover.HoverEnvConfig.ctrl_dt = 0.02
static

◆ episode_length

int rl_stl.envs.skydio_x2.hover.HoverEnvConfig.episode_length = 500
static

◆ fluid

bool rl_stl.envs.skydio_x2.hover.HoverEnvConfig.fluid = True
static

◆ impl

str rl_stl.envs.skydio_x2.hover.HoverEnvConfig.impl = "jax"
static

◆ naconmax

int rl_stl.envs.skydio_x2.hover.HoverEnvConfig.naconmax = 0
static

◆ njmax

int rl_stl.envs.skydio_x2.hover.HoverEnvConfig.njmax = 0
static

◆ reset

ResetConfig rl_stl.envs.skydio_x2.hover.HoverEnvConfig.reset = ResetConfig()
static

◆ reward

RewardConfig rl_stl.envs.skydio_x2.hover.HoverEnvConfig.reward = RewardConfig()
static

◆ sim_dt

float rl_stl.envs.skydio_x2.hover.HoverEnvConfig.sim_dt = 0.01
static

◆ stl

STLRewardConfig rl_stl.envs.skydio_x2.hover.HoverEnvConfig.stl = STLRewardConfig()
static

◆ target

tuple rl_stl.envs.skydio_x2.hover.HoverEnvConfig.target = (0.0, 0.0, 1.5)
static

◆ target_range

tuple rl_stl.envs.skydio_x2.hover.HoverEnvConfig.target_range = (0.0, 0.0, 0.0)
static

◆ termination

TerminationConfig rl_stl.envs.skydio_x2.hover.HoverEnvConfig.termination = TerminationConfig()
static

The documentation for this class was generated from the following file: